Robot program translation
Move a cell to another robot brand without starting over
Altitude translates robot programs between 19 brands, in either direction, with every register, position, signal and label mapped once for the whole project.
FANUC PICK.LS · Teach pendant
ABB Pick.mod
KUKA Pick.src
URScript pick.script
One mapping for the whole project
P[2:Above_Pick] pAbovePick
DI[101:Case_Present] diCasePresent
DO[101:Gripper_Close] doGripperClose
Line 8: the wait’s TIMEOUT,LBL[90] branch is reported for review
One mapping for the whole project
P[2:Above_Pick] XABOVE_PICK
DI[101:Case_Present] $IN[101]
DO[101:Gripper_Close] $OUT[101]
Line 8: the wait’s TIMEOUT,LBL[90] branch is reported for review
One mapping for the whole project
P[2:Above_Pick] above_pick
DI[101:Case_Present] digital in 0
DO[101:Gripper_Close] digital out 0
Line 8: the wait’s TIMEOUT,LBL[90] branch is reported for review
How it works
Step by step
- 1
Read the whole project
Every module, declaration, position and signal is read before any target is written, so shared names stay consistent.
- 2
Fix the mapping
Each register, flag, position, signal, label and program gets its name in the target once, for the whole project.
- 3
Translate
Structure first, then motion, then logic, then recovery, where the languages differ most.
- 4
Review in the target’s own view
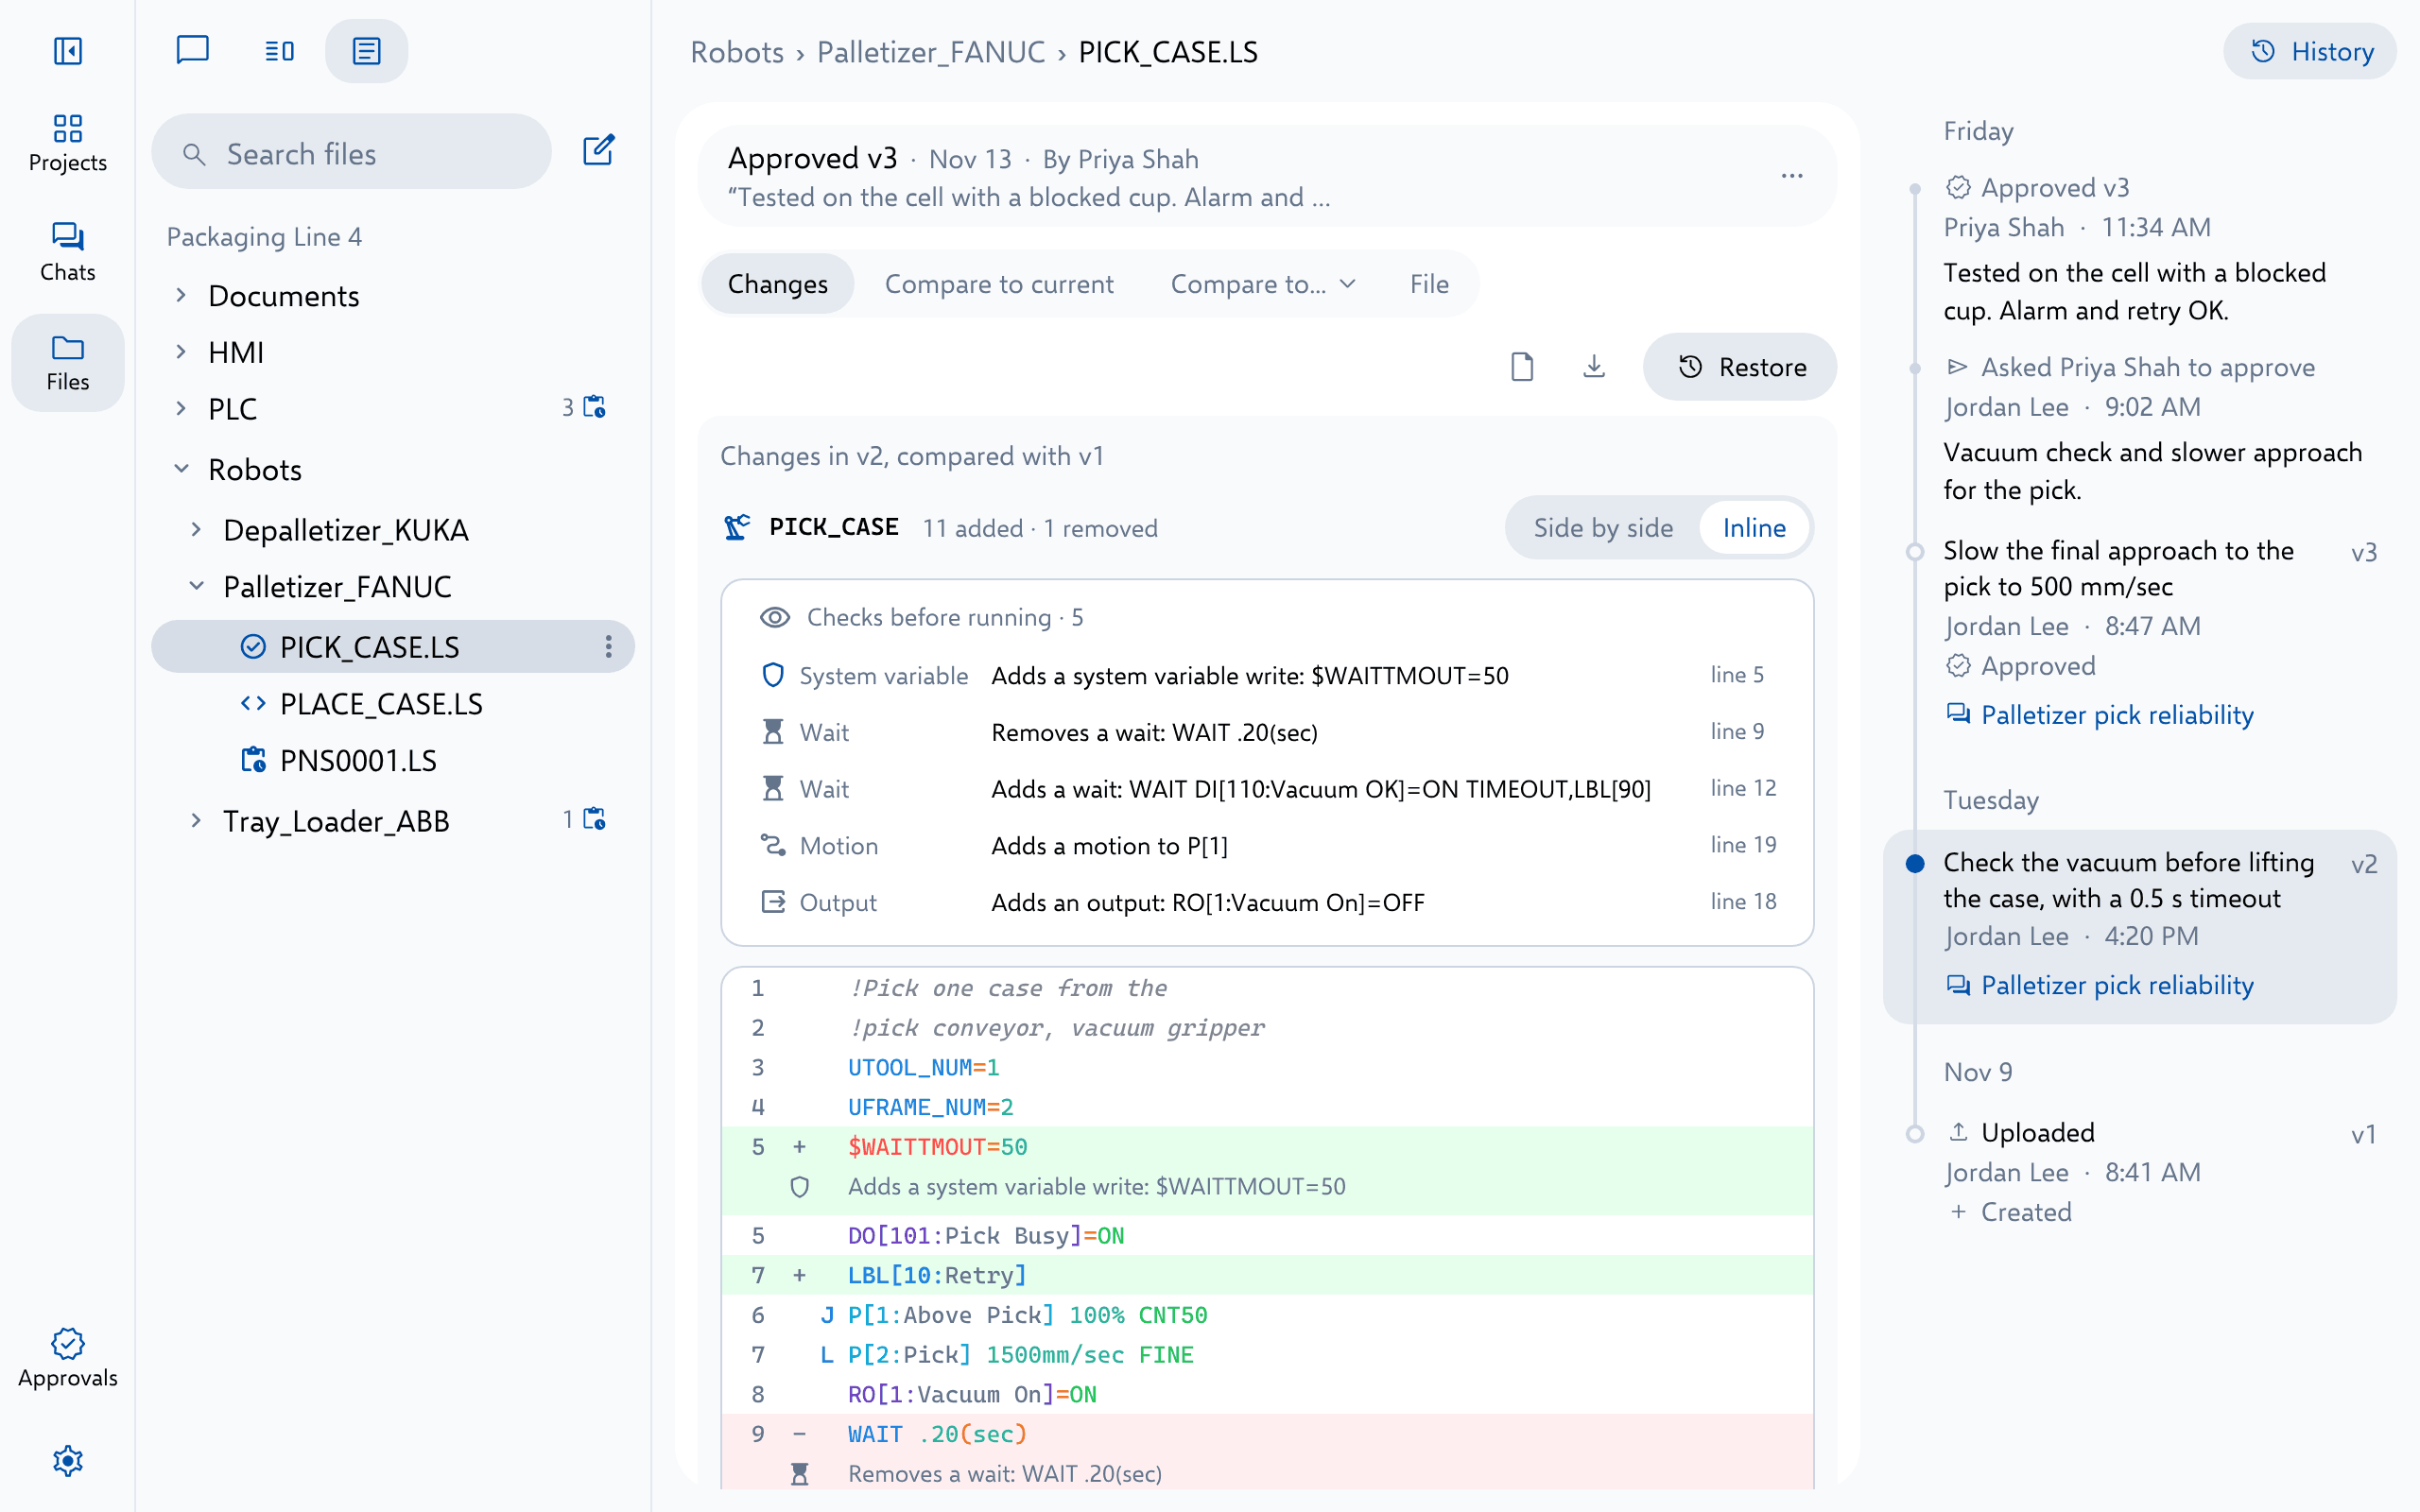
The translated programs open in the brand’s own view, with a diff of every later change and its history.
Every difference reported
A construct the target lacks is expanded into the target’s own statements, and every expansion that changes what the robot does is reported.
- Any of 19 brands to any other
- One mapping of names for the whole project
- Detailed mappings for ABB RAPID and FANUC TP in either direction
- Each brand drawn in its own view, with its own diff
Brands
- FANUC
- ABB
- KUKA
- Yaskawa
- Universal Robots
- Epson
- Kawasaki
- Stäubli
- DENSO
- Mitsubishi
- NACHI
- COMAU
- Omron
- Hyundai
- Doosan
- Yamaha
- Techman
- Panasonic
- Daihen OTC
Platforms
On the platforms you run
FAQ
Questions teams ask first
Does it change the source programs?
Does it translate a whole project or one program?
Keep exploring
More ways teams use Altitude
See it on the work your team does every day
We'll walk through the workflows that matter most to your team, on the PLC, robot and HMI platforms you run, from review and troubleshooting to documents and migration.